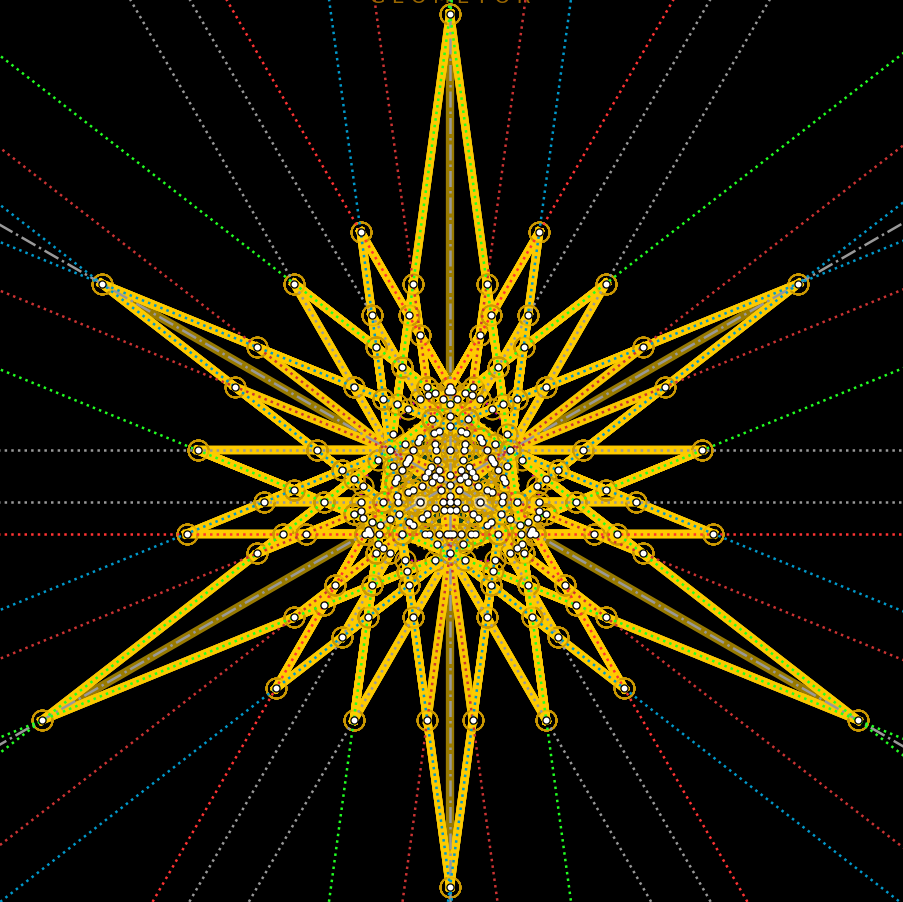
X511–X565
Centers on the Line at Infinity & Vector Directions
X511–X565 (Centers on the Line at Infinity & Vector Directions) — 16 representative centers (from 55 in collection) constructed on acute reference triangle \((a, b, c) = (5, 6, 7)\) with unit baseline AB = \(1\).
Group Preamble — Centers on the line at infinity: X511-X526 (Centers on the lines at infinity: X511-X526)
In barycentric coordinates, the line at infinity, L, is the set of points X =\(x : y : z\) satisfying \(x + y + z = 0\). The isogonal conjugate of L, given by a^2 y z + b^2 z x + c^2 x y = 0, is the circumcircle (e.g., X98-X112).
The collection of collinearities reported below for each of the centers on L comprises a family of parallel lines.
Barycentrics \(x: y : z\) (and trilinears) for X30, X511-X526, and many other triangle centers on L, are polynomials in (a,b,c). For example, barycentrics for X511 are \(p(a,b,c) : p(b,c,a) : p(c,a,b)\), where
p(a,b,c) = \(a^{2}(a^{2}b^{2} + a^{2}c^{2} - b^{4} - c^{4})\).
Such polynomials comprise a family that can be partitioned into two subfamilies: even and odd. Each subfamily can be generated as linear combination of polynomials in certain bases. For example, a basis for the even polynomials of degrees 1 to 4 follows:
A basis for the odd polynomials of degrees 1 to 2 follows:
Group Preamble — Centers X527-X565 (Centers X527-X565. Jan 1 2001)
Centers X527-X565 were added to ETC on the first day of 2001.

X511ISOGONAL CONJUGATE OF X98

X512ISOGONAL CONJUGATE OF X99

X513ISOGONAL CONJUGATE OF X100

X514ISOGONAL CONJUGATE OF X101

X515ISOGONAL CONJUGATE OF X102

X516ISOGONAL CONJUGATE OF X103

X517ISOGONAL CONJUGATE OF X104

X518ISOGONAL CONJUGATE OF X105

X519ISOGONAL CONJUGATE OF X106

X520ISOGONAL CONJUGATE OF X107

X521ISOGONAL CONJUGATE OF X108

X522ISOGONAL CONJUGATE OF X109

X523ISOGONAL CONJUGATE OF X110

X524ISOGONAL CONJUGATE OF X111

X525ISOGONAL CONJUGATE OF X112

X526ISOGONAL CONJUGATE OF X476

X527DIRECTION OF VECTOR AX + BX + CX, where X = X7

X528DIRECTION OF VECTOR AX + BX + CX, where X = X11

X529DIRECTION OF VECTOR AX + BX + CX, where X = X12

X530DIRECTION OF VECTOR AX + BX + CX, where X = X13

X531DIRECTION OF VECTOR AX + BX + CX, where X = X14

X532DIRECTION OF VECTOR AX + BX + CX, where X = X17

X533DIRECTION OF VECTOR AX + BX + CX, where X = X18

X534DIRECTION OF VECTOR AX + BX + CX, where X = X19

X535DIRECTION OF VECTOR AX + BX + CX, where X = X36
X535 lies on the line at infinity.

X536DIRECTION OF VECTOR AX + BX + CX, where X = X37

X537DIRECTION OF VECTOR AX + BX + CX, where X = X38

X538DIRECTION OF VECTOR AX + BX + CX, where X = X39

X539DIRECTION OF VECTOR AX + BX + CX, where X = X54

X540DIRECTION OF VECTOR AX + BX + CX, where X = X58
X540 lies on the line at infinity.

X541DIRECTION OF VECTOR AX + BX + CX, where X = X74

X542DIRECTION OF VECTOR AX + BX + CX, where X = X98

X543DIRECTION OF VECTOR AX + BX + CX, where X = X99

X544DIRECTION OF VECTOR AX + BX + CX, where X = X101

X545DIRECTION OF VECTOR AX + BX + CX, where X = X190

X546MIDPOINT OF X4 AND X5

X547MIDPOINT OF X2 AND X5

X548MIDPOINT OF X5 AND X20

X549MIDPOINT OF X2 AND X3

X550MIDPOINT OF X3 AND X20

X551MIDPOINT OF X1 AND X2

X552POINT MAIA I

X553POINT MAIA II

X554(X1,X13)-ANSWER TO QUESTION A

X555(X1,X158)-ANSWER TO QUESTION A

X556(X1,X75)-ANSWER TO QUESTION A


X558(X1,X57)-ANSWER TO QUESTION A

X559(X1,X15)-ANSWER TO QUESTION A

X5604th POWER POINT

X561ISOGONAL CONJUGATE OF 4th POWER POINT

X562TRILINEAR QUOTIENT X2*X50/X49

X563TRILINEAR PRODUCT X47*X48

X564INTERSECTION OF LINES X1X_1048 AND X(47,91)
